Troubleshooting Magnetostrictive Displacement Sensors: Inaccurate Readings, Jumps, No Output
The failure rate of magnetostrictive displacement sensors is in fact low, but once the reading is wrong the line has to stop. This article lists the most common site problems in a "symptom → cause → action" pattern, so you can work through them in order and avoid detours.
Symptom 1: no output / reading stuck at 0 or full scale
Do not open the head first. Check supply voltage and polarity ahead of any disassembly — reverse polarity burns the unit.
- Supply: first measure the voltage at the sensor: +24 V (20.4–28.8 V). Reverse-polarity to −30 V and over-voltage 36 V are protection limits, not the working range; isolation is typically 500 Vdc. Voltage-output load must be ≥5 kΩ. Check fuses and reversed polarity together;
- Loose wiring: plug not fully seated, oxidised pins — especially on bus types, reseat and tighten first;
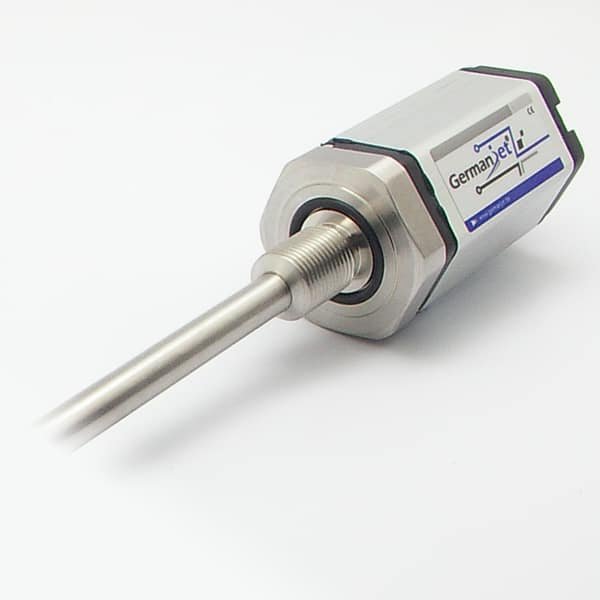
- Missing or reversed position magnet: after an in-cylinder rod change the magnet was forgotten, or it was fitted outside the measuring range, so the sensor receives no magnetic field and no echo. Lamps: electronics-head LEDs.
Swapping supply and signal burns the sensor — Series 18 four-pin voltage is unforgiving; see Series 18. Multimeter steps: five-step check.
Symptom 2: jumping, unstable values
- Electromagnetic interference: signal cable running parallel with power cable is the leading cause; increase spacing or add screening. A reading steady at standstill but jittering as it moves points to a magnet bracket; a jump at machine start-up points to interference rather than a loose magnet;
- Incorrect screen earthing: change to single-end earthing and check that the earth point is clean;
- Loose position magnet: slight axial movement or radial wobble of the magnet drifts the echo position; tighten and recheck;
- Large supply ripple: a poor switch-mode supply; paralleling a filter capacitor often has an immediate effect.
Symptom 3: inaccurate measurement, a fixed offset
- Zero not calibrated: redo the two-point recalibration (slope and datum) and confirm that mechanical zero corresponds to the reading. A reading pinned at an end value inside a dead zone is normal, not a fault;
- Wrong measuring-range setting: the range parameter in the controller does not match the sensor's actual range, so proportional conversion is biased;
- Magnet outside the measuring zone: check whether the magnet has travelled beyond the effective zone of the rod.
Symptom 4: intermittent loss of data / communications drop-out (bus types)
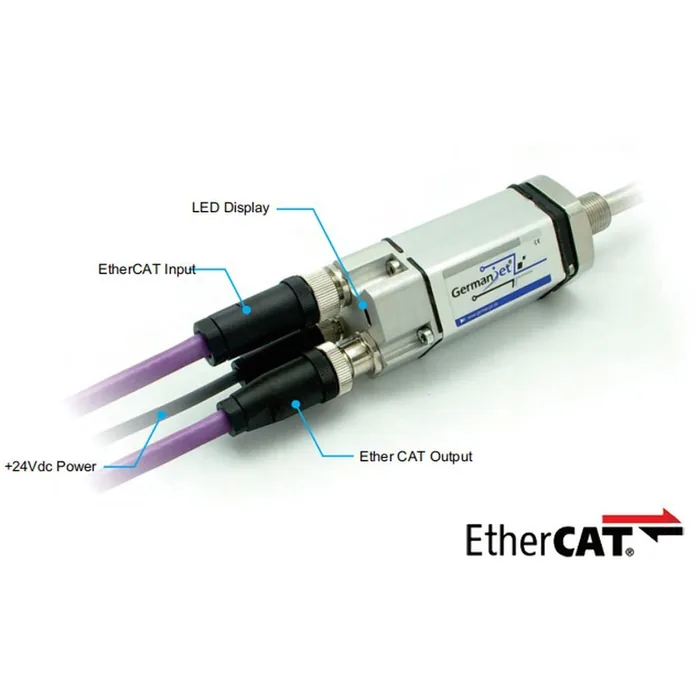
- Terminating resistors: fit 120 ohm resistors at both ends of the CAN bus; on Profibus, switch both end plugs ON and leave them powered. Missing or misplaced terminators cause frame loss on long runs;
- Node address clash: two slaves with the same address make the bus drop out repeatedly;
- Water or oil in the connector: even a high protection rating fails if the connector seal fails; inspect M12 O-rings regularly.
Frequently Asked Questions
Q: The sensor shows no output. What should I check first?
Measure the voltage at the sensor and confirm it sits between 20.4 and 28.8 V (24 V nominal), then confirm the polarity is not reversed, which burns the unit. Note that reverse-polarity protection to -30 V and over-voltage 36 V are protection limits, not the working range, and that a voltage-output type needs a load of at least 5 k ohm. Check fuses and polarity together and do not dismantle the electronics head first.
Q: The reading keeps jumping. How do I tell a mechanical problem from interference?
Look at when it happens. A reading that is steady at standstill but jitters as the machine moves points to a magnet bracket transmitting vibration; a jump the moment the machine starts points to electrical interference. For interference, start with the cabling: signal cable running parallel with power cable is the leading cause, so increase spacing or add screening, then change the screen to single-end earthing and confirm the earth point is clean. If the switch-mode supply has large ripple, paralleling a filter capacitor often has an immediate effect.
Q: The reading has a fixed offset. Is the sensor faulty?
Usually not. Check three things in order: whether zero was calibrated (redo the zero calibration and confirm mechanical zero corresponds to the reading); whether the range parameter in the controller matches the sensor's actual range (if not, proportional conversion is biased); and whether the magnet has travelled outside the rod's effective zone. If it is a genuine system offset, recalibrate with the two-point method. Note that a magnet sitting inside an end dead zone with the reading pinned at an end value is normal, not a fault.
Q: A bus version loses data or drops communications intermittently. Where do I start?
Start with the terminating resistors: 120 ohm at both ends of the CAN bus, and on Profibus both end plugs switched ON and left powered, since missing or misplaced terminators cause frame loss on long runs. Then check for a node address clash, because two slaves sharing an address make the bus drop out repeatedly. Finally check for water or oil in the connector: even a high protection rating fails if the connector seal fails, so inspect the M12 O-rings regularly.
Related Products
Related Applications
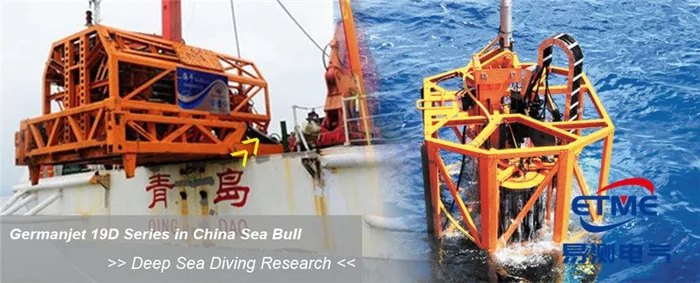
Series 19D Split-Type Process Displacement Sensor Application Cases
View Details
Series 19H Cylinder-Integrated Process Displacement Sensor Application Cases
View Details
Series 19P External Rod Process Displacement Sensor Application Cases
View Details